Meest populaire keuze – Scherpste prijs!

Amazon· Bekende aanbieder
€ 53,49
1 tot 2 dagenGratis verzending
Check de website voor de levertijd | Gratis bezorgd > €25,-

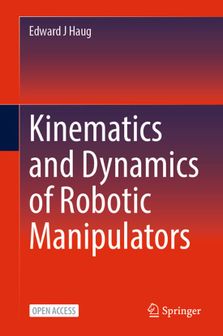
This open access book presents a differential geometric formulation for kinematics and dynamics of roboticmanipulators, both nonredundant and redundant, resulting in a rigorous treatment of ordinarydifferential equations (ODE) for manipulator dynamics that are ideally suited for either input oroperational space robot control. The author assumes no background in abstract topology ofdifferential geometry; mathematical and computational concepts are introduced using onlymultivariable calculus at the undergraduate level applied to model engineering applications.Examples are treated throughout to provide a foundation for understanding modern conceptsand techniques that have often only been presented at an abstract mathematical level intheoretical robotics literature that is not generally accessible to the engineer. The formulationpresented in this book further obtains ordinary differential equations that represent thedynamics of robotic systems that are reliably solved numerically with established Runge-Kuttamethods. Lagrange multipliers that are ill-suited for robotic control are avoided . Examples ofrealistic manipulators are presented with numerical results that demonstrate the desiredperformance of modern analytical and computational methods.
Heb jij dit product in bezit en wil je graag je mening geven? Start dan hieronder met het schrijven van je review. Afhankelijk van de details duurt het schrijven van een review gemiddeld tussen de 3 en 10 minuten. Met jouw mening help je andere bezoekers een betere keuze te maken én maak je iedere maand kans op €250,-! Klik hier voor de actievoorwaarden.
